3D PERCEPTION & WORLD MODELS

Zhimin Liao

廖智民

Ph.D. Student · Artificial Intelligence

Xi’an Jiaotong University

I study how machines represent the 3D world and anticipate what comes next, with a focus on autonomous driving.

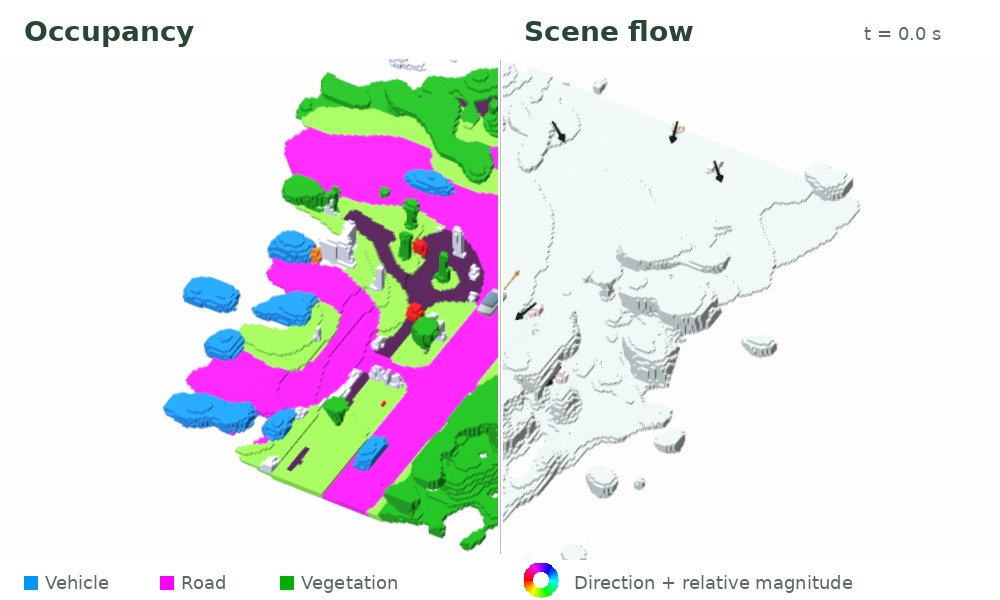
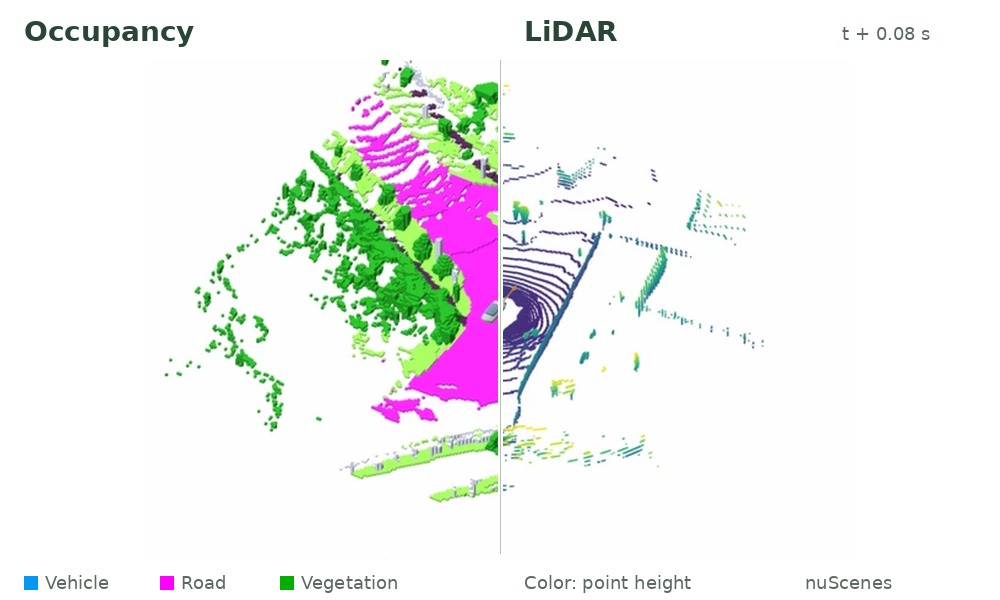
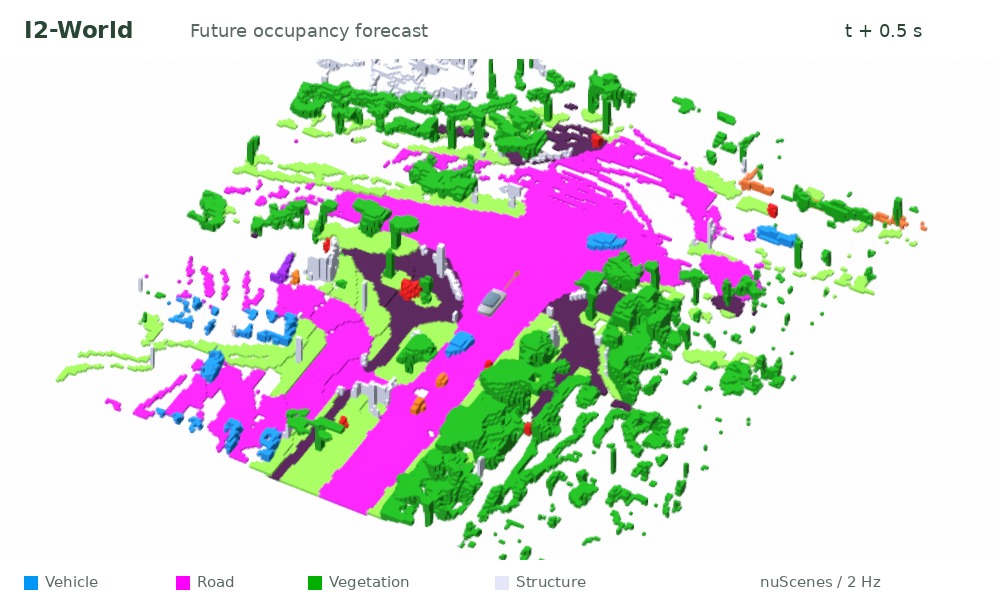
My research spans 3D occupancy, scene flow, and efficient 4D scene forecasting — building sparse and tokenized representations of a changing world.

Currently, I’m also a Perception Algorithm Intern at Horizon Robotics.
Portrait of Zhimin Liao
WORKING AT THE INTERSECTION OF 3D perception Scene dynamics World models ↓

00

Background.

教育与工作经历

From automation to artificial intelligence, with a focus on understanding the world in 3D.

Education

教育背景
  1. — PRESENT

    Xi’an Jiaotong University

    Ph.D. in Artificial Intelligence

    Expected June 2028

  2. —

    Jilin University

    Bachelor’s in Automation

Work Experience

工作经历
  1. — PRESENT

    Horizon Robotics

    Perception Algorithm Intern
01

Selected work.

All publications on Scholar
Earlier & collaborative work06 PAPERS
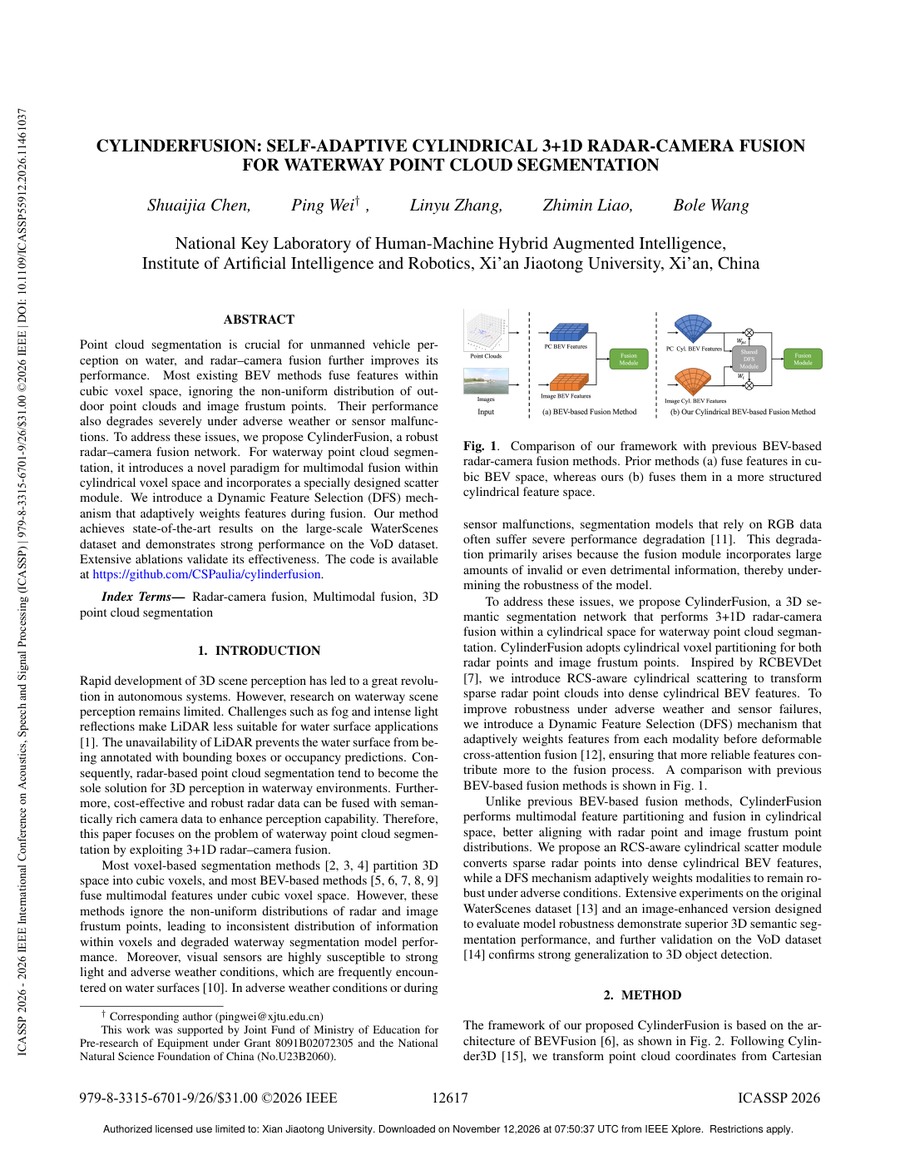
Complete first page of CylinderFusion, including title, authors and abstract

ICASSP · 2026

CylinderFusion: Self-Adaptive Cylindrical 3+1D Radar-Camera Fusion for Waterway Point Cloud Segmentation

Shuaijia Chen, Ping Wei, Linyu Zhang, Zhimin Liao, Bole Wang

Paper Code
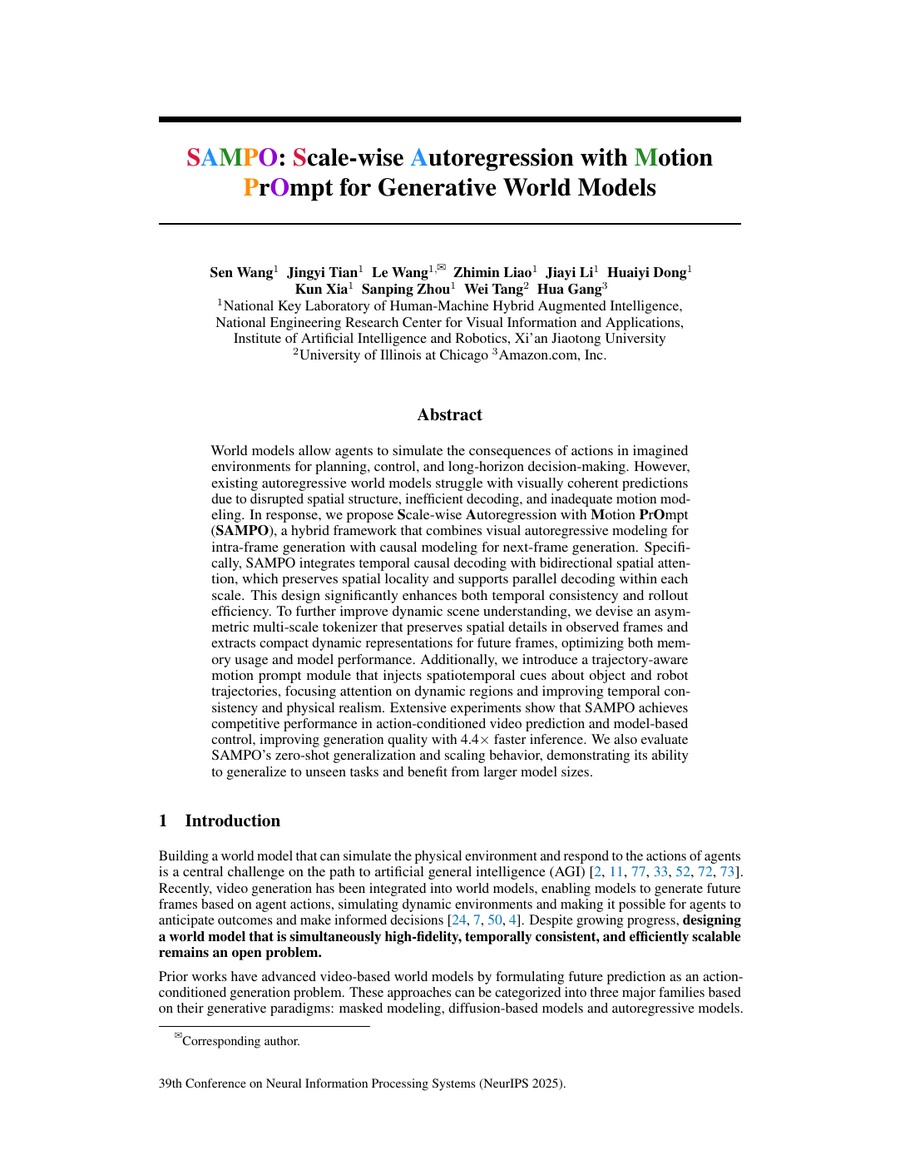
Complete first page of SAMPO: Scale-wise Autoregression with Motion Prompt for Generative World Models, including title, authors and abstract

NeurIPS · 2025

SAMPO: Scale-wise Autoregression with Motion Prompt for Generative World Models

Sen Wang, Jingyi Tian, Le Wang, Zhimin Liao, et al.

Paper PDF arXiv
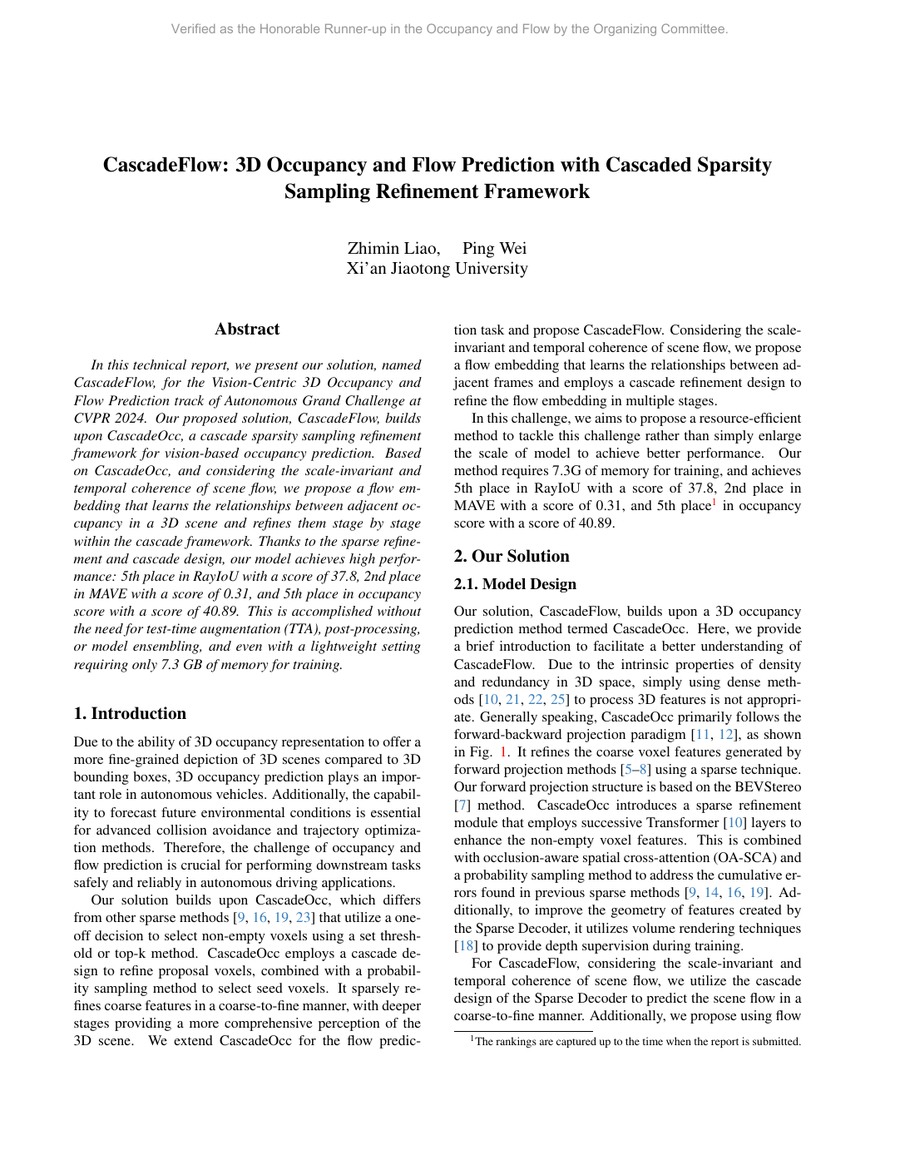
First page of the CascadeFlow technical report, including title, authors and abstract

CVPR Autonomous Grand Challenge · 2024

CascadeFlow: 3D Occupancy and Flow Prediction with Cascaded Sparsity Sampling Refinement Framework

Zhimin Liao, Ping Wei

Paper Scholar
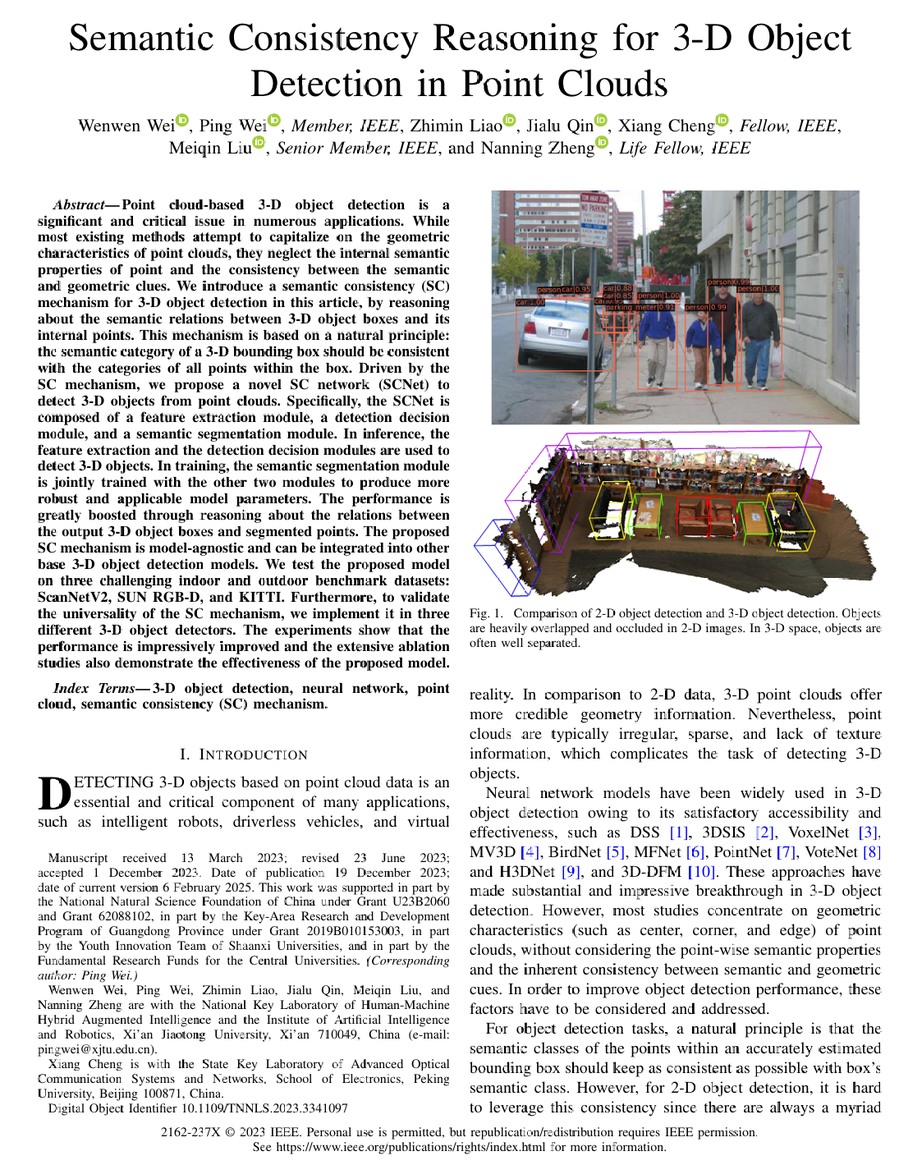
First page of Semantic Consistency Reasoning for 3-D Object Detection in Point Clouds, including title, authors and abstract

IEEE TNNLS · 2025

Semantic Consistency Reasoning for 3-D Object Detection in Point Clouds

Wenwen Wei, Ping Wei, Zhimin Liao, et al.

Paper Scholar
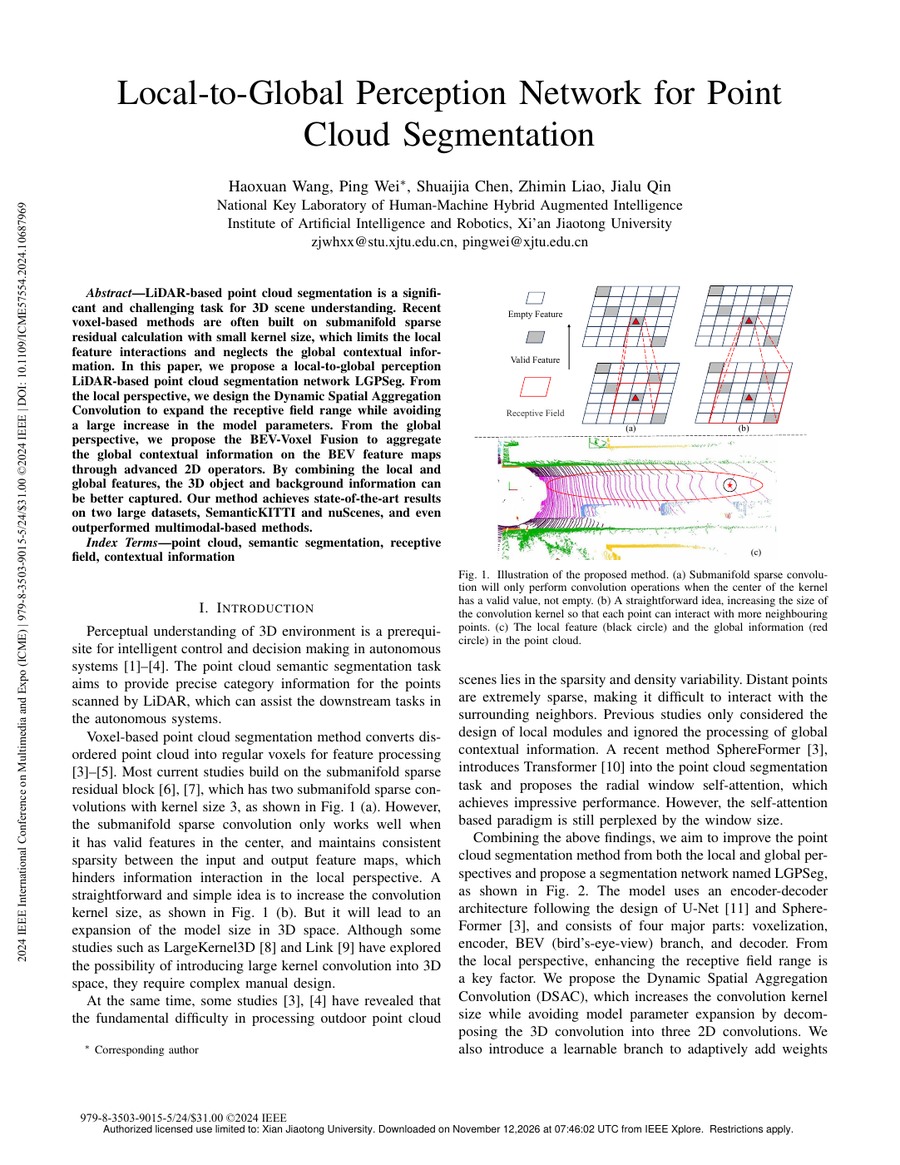
Complete first page of Local-to-Global Perception Network for Point Cloud Segmentation, including title, authors and abstract

ICME · 2024

Local-to-Global Perception Network for Point Cloud Segmentation

Haoxuan Wang, Ping Wei, Shuaijia Chen, Zhimin Liao, Jialu Qin

Paper Scholar
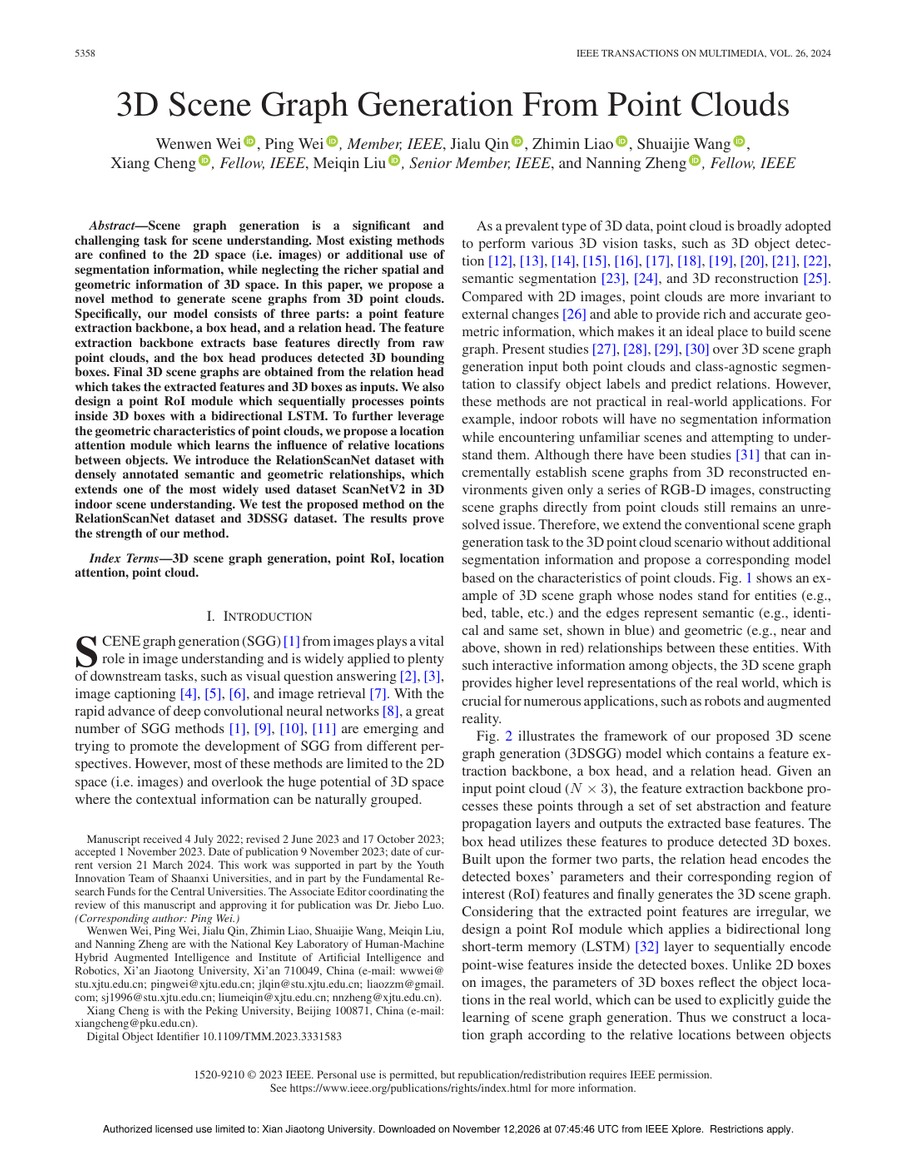
Complete first page of 3D Scene Graph Generation from Point Clouds, including title, authors and abstract

IEEE TMM · 2024

3D Scene Graph Generation from Point Clouds

Wenwen Wei, Ping Wei, Jialu Qin, Zhimin Liao, et al.

Paper Scholar

02

Awards.

获奖荣誉

LET’S CONNECT

Good research starts
with a conversation.

Citation

Copy the BibTeX entry for this publication.